Symmetric vs Asymmetric Circle Grids for Camera Calibration
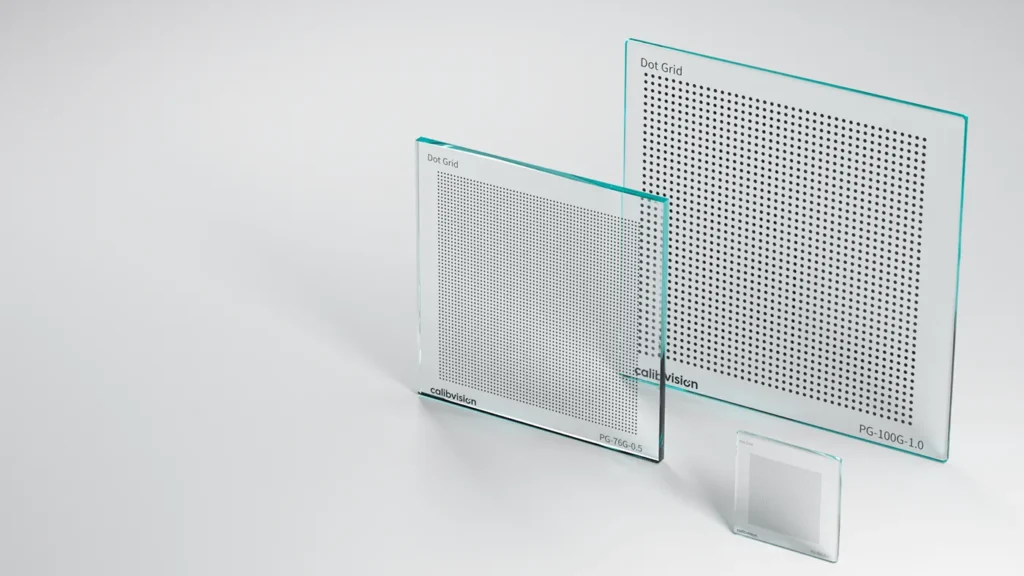
Circle grids are the third common OpenCV calibration pattern, in two layouts. The asymmetric (staggered) grid removes the 180° orientation ambiguity of the symmetric grid and packs more points, which is why it is the recommended layout. How findCirclesGrid counts patternSize for each (the (4,11) gotcha), why circle centroids carry a perspective bias, blob-detector tuning, and how substrate sets the accuracy ceiling.
Camera Calibration Pattern Types: Checkerboard, ChArUco, Dot Grid, and AprilGrid Compared
A calibration pattern gives a camera a field of reference points with known geometry. The families differ in feature type (corner, centroid, coded marker), whether points are individually identified, and which software expects them. Overview of checkerboard, ChArUco, dot/circle grid and AprilGrid, how to choose by toolchain and application, and why the substrate sets the accuracy ceiling.
Checkerboard vs Dot Grid Calibration Targets: Corner Detection, Centroid Bias, and How to Choose
A checkerboard is detected by its corners (saddle points); a dot grid by the centroids of its dots. Corners are projectively invariant — no systematic offset under perspective; dot centroids are lower-noise and denser but carry a perspective/eccentricity bias unless the detector models the ellipse. What that means for accuracy, which software expects which pattern, substrate accuracy from ±0.5 µm, and how to choose.
ChArUco Calibration Boards: Coded-Marker Targets for Partial-View and Multi-Camera Calibration
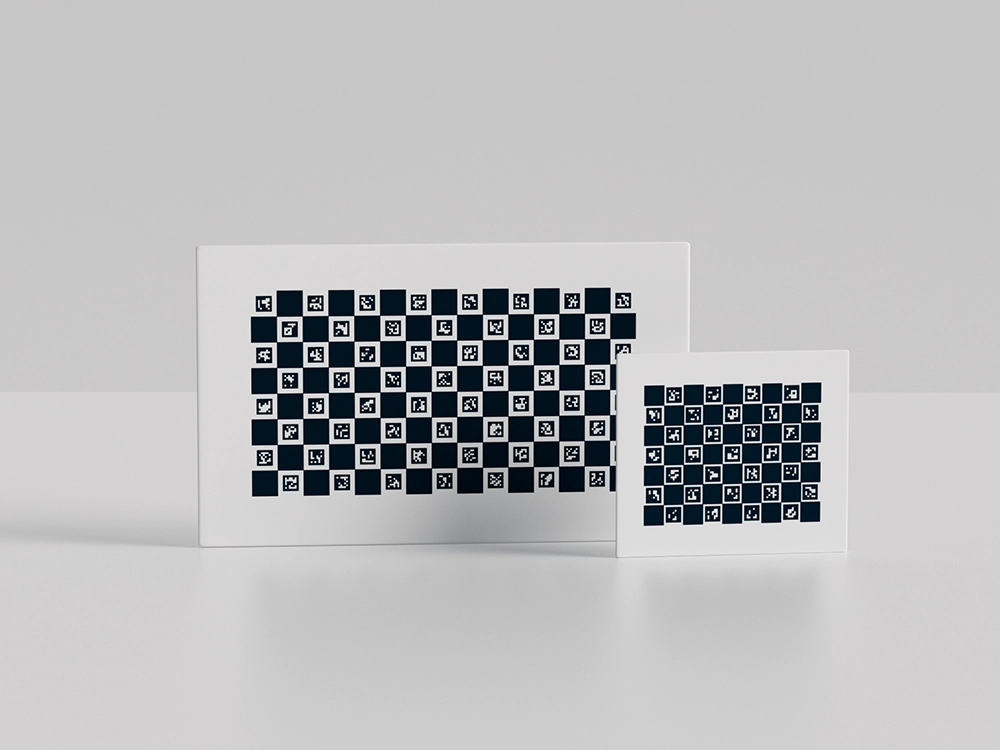
A ChArUco board is a checkerboard with coded ArUco markers in its white squares — sub-pixel corners plus a unique ID at each one, so calibration succeeds even when the board is tilted, occluded or only partly in frame. What it is, why it beats a plain checkerboard, the four specs that matter, how to choose a configuration and substrate, how it differs from AprilGrid, and how to order the right target.