LiDAR–Camera Calibration Targets: How to Choose a Board Both Sensors Can See
A camera reads the pattern; a lidar reads the plane and edges. This guide compares four target types and shows how to size a board for both sensors.
The Best Calibration Targets and Test Charts: A Complete Comparison by Use
A comparison of the most widely used calibration targets and test charts, organised by what they measure rather than lumped together. Geometric targets — checkerboard, ChArUco, dot grid, AprilGrid — solve camera geometry and distortion; resolution and image-quality charts — USAF 1951, ISO 12233, ISO 15739 — measure sharpness, resolution and noise. Definitions, applications, the software each pairs with, and where to buy.
MATLAB Camera Calibration with a Checkerboard: Board Size, the Even/Odd Rule, and the Calibrator App
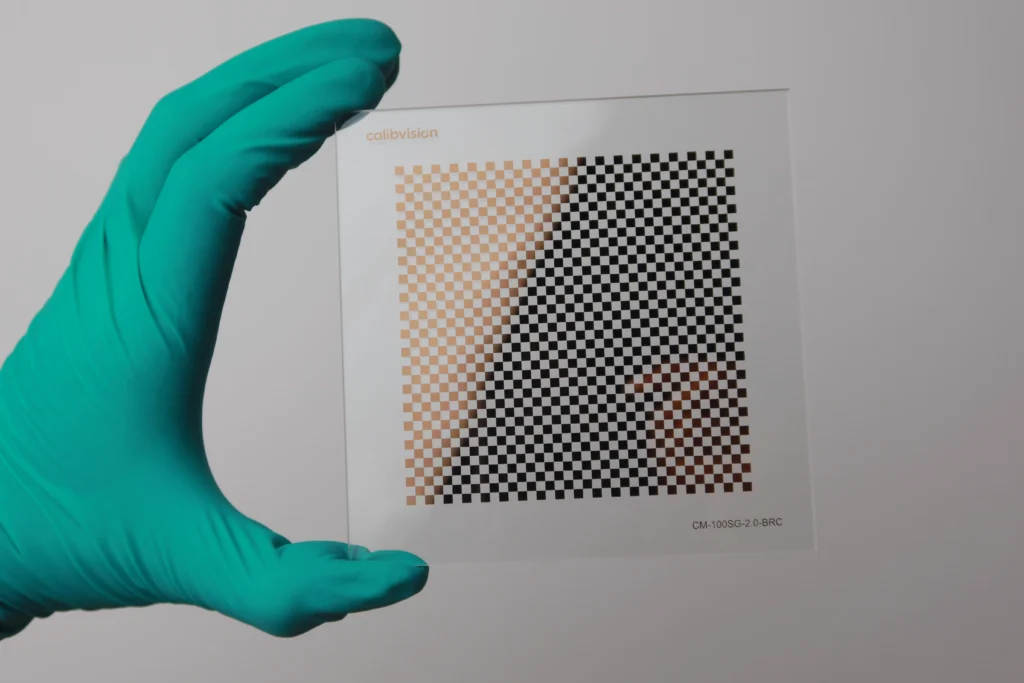
MATLAB’s Camera Calibrator app calibrates from a checkerboard, but it is stricter than OpenCV: it needs a board with an even number of squares on one edge and an odd number on the other, which produces two black and two white corners so the app can fix orientation and origin. Board size is counted in squares (points are the interior corners), plus the detectCheckerboardPoints / generateCheckerboardPoints / estimateCameraParameters workflow, stereo and fisheye, and why the target sets the accuracy ceiling.
Camera Calibration Pattern Types: Checkerboard, ChArUco, Dot Grid, and AprilGrid Compared
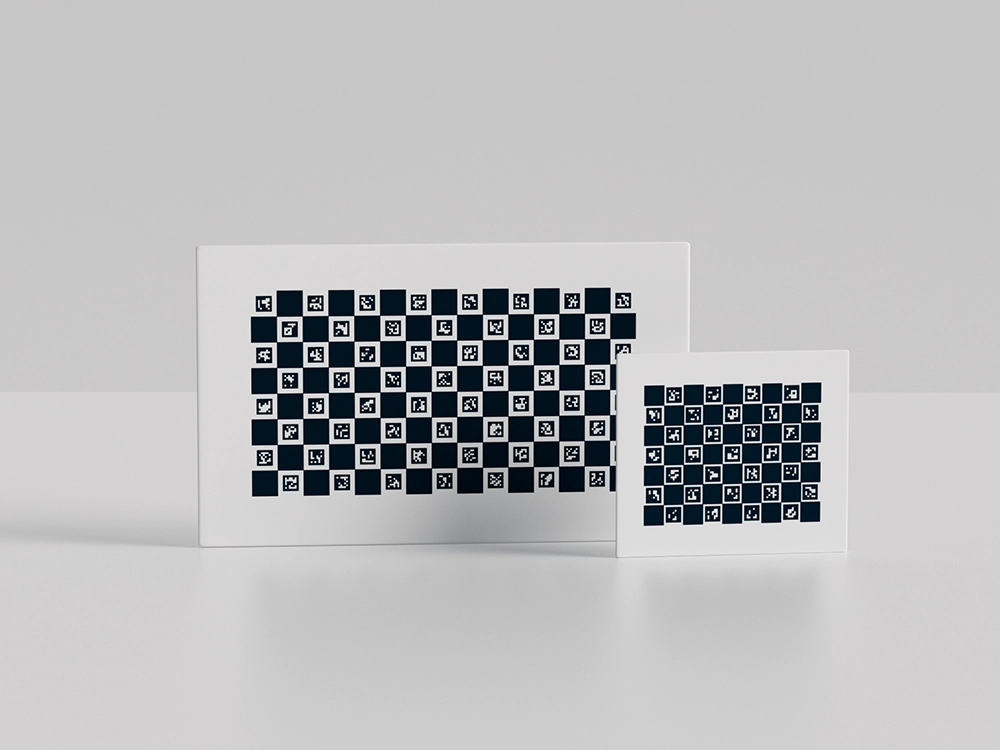
A calibration pattern gives a camera a field of reference points with known geometry. The families differ in feature type (corner, centroid, coded marker), whether points are individually identified, and which software expects them. Overview of checkerboard, ChArUco, dot/circle grid and AprilGrid, how to choose by toolchain and application, and why the substrate sets the accuracy ceiling.
Checkerboard vs Dot Grid Calibration Targets: Corner Detection, Centroid Bias, and How to Choose
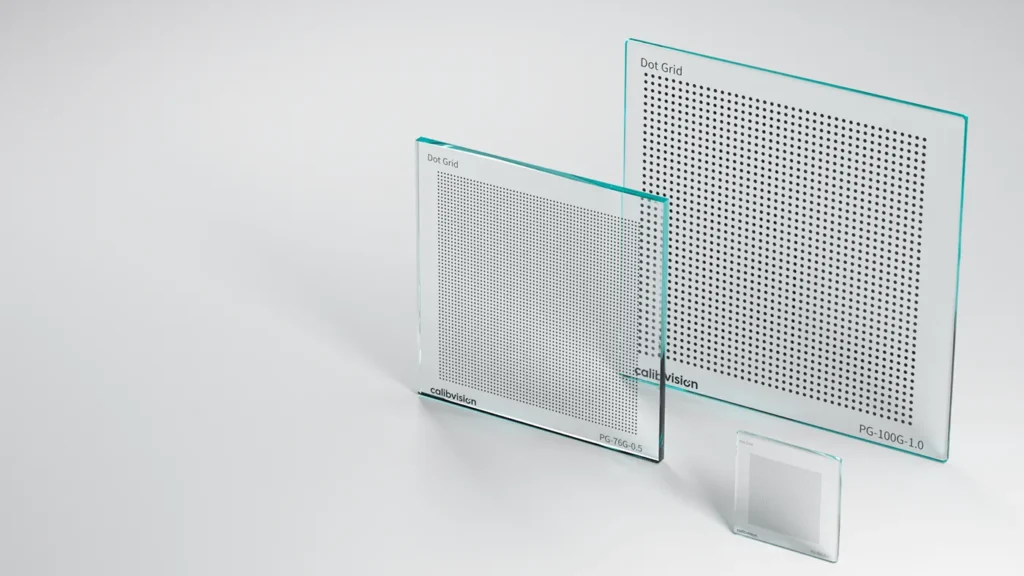
A checkerboard is detected by its corners (saddle points); a dot grid by the centroids of its dots. Corners are projectively invariant — no systematic offset under perspective; dot centroids are lower-noise and denser but carry a perspective/eccentricity bias unless the detector models the ellipse. What that means for accuracy, which software expects which pattern, substrate accuracy from ±0.5 µm, and how to choose.
Camera Calibration Targets: How to Choose the Right Pattern, Substrate, and Accuracy
A camera calibration target is a precisely patterned plate that gives a camera a field of known reference points. Choosing one comes down to pattern type, substrate and accuracy, physical size, and toolchain fit — and the target, not the algorithm, sets your accuracy ceiling. A navigational overview that links to each in-depth guide.